KAIST Develops AI-Powered Robot Dog That Switches Gaits to Handle Rough Terrain
Researchers at KAIST have developed a new AI system. This system makes a four-legged robot capable of changing the way it moves depending on the terrain around it.

July 17, 2026 by Carl
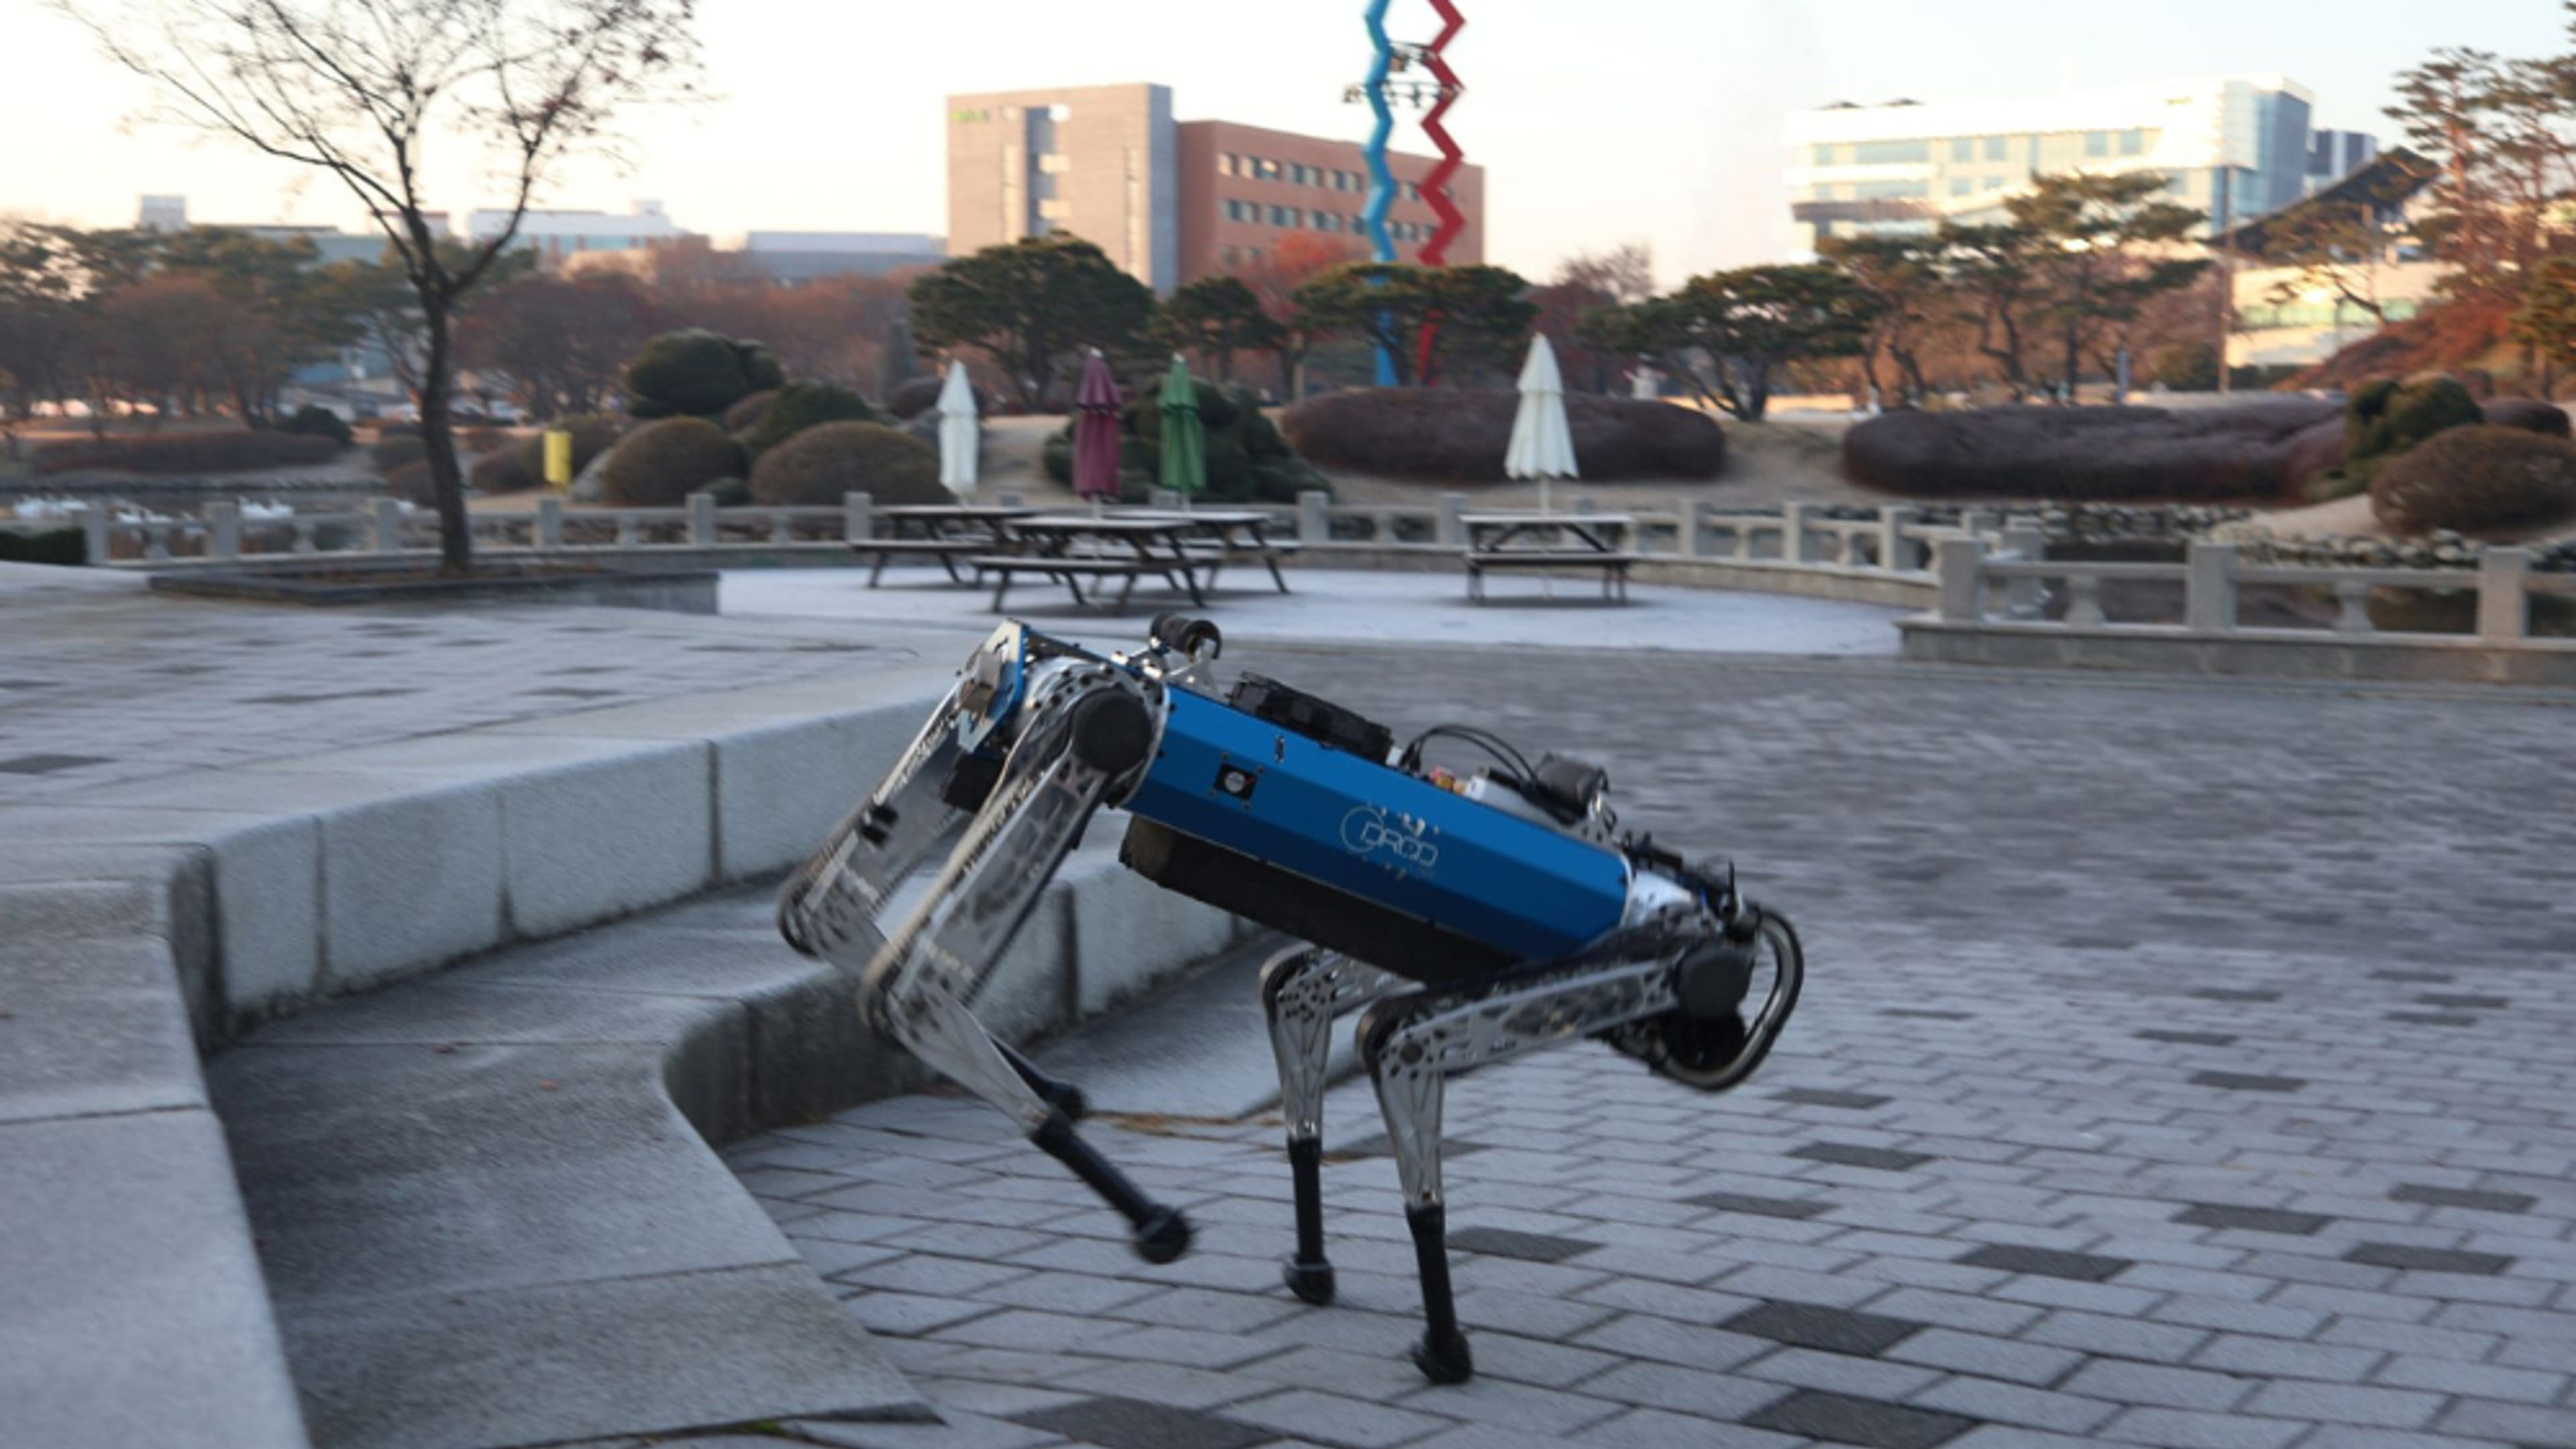
Researchers at the Korea Advanced Institute of Science and Technology (KAIST) have developed a new artificial intelligence (AI) system. This system makes a four-legged robot capable of changing the way it moves depending on the terrain around it. This robot is not like those typical ones that depend on individual commands for every movement. In fact, it can switch between multiple gaits like walking/running or even jumping.
This new system proves to be super beneficial because these robot dogs can be deployed for a variety of missions that could be dangerous for humans. These missions include search-and-rescue or disaster response, as well as defense and industrial inspection, etc.
The research was led by Professor Hae-Won Park from KAIST’s Department of Mechanical Engineering in collaboration with Korea University, the Agency for Defense Development (ADD), and DIDEN Robotics. Their study was published in the journal Science Robotics.
A Smarter Way for Robots to Move
The team developed a new AI framework called Action Pretrained Transformer-based Reinforcement Learning (APT-RL). It is worth noting that this system doesn’t work like the one used in those conventional quadruped robots that use separate controllers for each type of movement. In fact, what APT-RL does is it combines a variety of locomotion skills into a single controller. Now that’s something super impressive, as it enables the robot to decide whether it should opt for walking, running, jumping, trotting, or even climbing as per the terrain.
Researchers, with the help of computer simulations, generated 180,000 optimized motion trajectories in order to train the robot. They did not depend on motion-capture recordings from humans or animals. Instead, they used trajectory optimization. With this method, they produced a dataset representing 15.5 hours of movement in just eight minutes.
The robot then learned through reinforcement learning. This is basically an AI method that improves performance through trial and error. This training enabled the robot to choose the most suitable movement strategy while maintaining balance across different obstacles.
Cameras and LiDAR Guide Every Step
The AI system relies entirely on onboard sensors and computing. A depth camera detects nearby obstacles. Moreover, a 2D LiDAR sensor scans the terrain farther ahead. When the robot combines the information provided by both these sensors, that’s when it understands what’s going on around it in real time. And after evaluating each and everything on its own, the robot prepares for upcoming obstacles before reaching them.
The researchers equipped the robot, KAIST HOUND, with this new control system. The robot successfully navigated indoor obstacle courses as well as outdoor environments. What’s even more interesting is that the robot did it all without any human guidance. It climbed stairs and crossed grassy slopes. It was even able to pass by rocky paths and stepping stones, along with gaps and exposed roots. And when fallen branches or logs came in its way, it navigated them successfully, too. On uneven ground, it typically used a stable trot. However, in case of a larger obstacle, it switched to a faster bounding gait.
The robot’s speed was also quite impressive. It reached an instantaneous top speed of 6 m/s (22 km/hr), while moving across rough terrain and jumping down a three-step staircase.
Better Performance and Future Potential
Researchers discovered that APT-RL has shown quite impressive and much better performance as compared to the existing learning and hierarchical methods. It delivered smoother gait transitions and improved energy efficiency. Not only this, but it also provided faster learning and better adaptability to unseen terrain without requiring retraining.
For now, the system mainly focuses on forward movement. And for navigation, it uses 2 basic gait styles. However, the team plans to further improve its capabilities in the future. The upcoming version is expected to cover longer distances and plan its routes on its own. And that version won’t only be capable of recognizing obstacles in its way, but people or other harmful objects, too.
As per Professor Hae-Won Park, this technology can prove to be a key building block for future physical AI. As its capabilities improve, agile quadruped robots like KAIST HOUND can be used for disaster response along with defense operations and exploration missions.
More articles on this topic
278 articles ReportWhat it Really Costs to Own a Personal Assistant Robot at Home
 ReportHumyn Labs Raises $47 Million to Build Real-World Training Data for Robotics
 ReportBoston Dynamics Selects GlobalFoundries as First Semiconductor Customer for Atlas Humanoid Trials
 ReportGenesis AI Raises $500 Million at a $3.5 Billion Valuation to Scale General-Purpose Robots
 ReportMultiway Robotics Showcases Intralogistics Solutions and Wheeled Humanoid at CeMAT ASIA
 ReportFORT Robotics Files Registration Statement for Public Listing Partnership
 ReportRobot Baristas are Learning to Reproduce the Art of Professional Coffee Making
 ReportTARSBOT and Aptiv Plan to Deploy 100 Industrial Robots Across 33 Factory Applications
 ReportSouth Korea Proposes $39 Million for Robot Actuators, Humanoid Batteries and AI Sensors
 ReportLoongson Completes ROS 2 Integration on Its Domestic Computing-Powered Intelligent Robot Vehicle
 ReportBoston Dynamics Puts Wheels on Atlas Humanoid to Test Reinforcement Learning and Motor Limits
 ReportAnt Group Open-Sources LingBot-Touch to Give Robots a Shared Sense of Touch
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.